Using AI Agents to Teach Robots Like Microduck to Walk in Simulation
Teaching a robot to navigate an obstacle course requires more than a walking policy. It must perceive its surroundings, maintain balance, and adjust its actions...
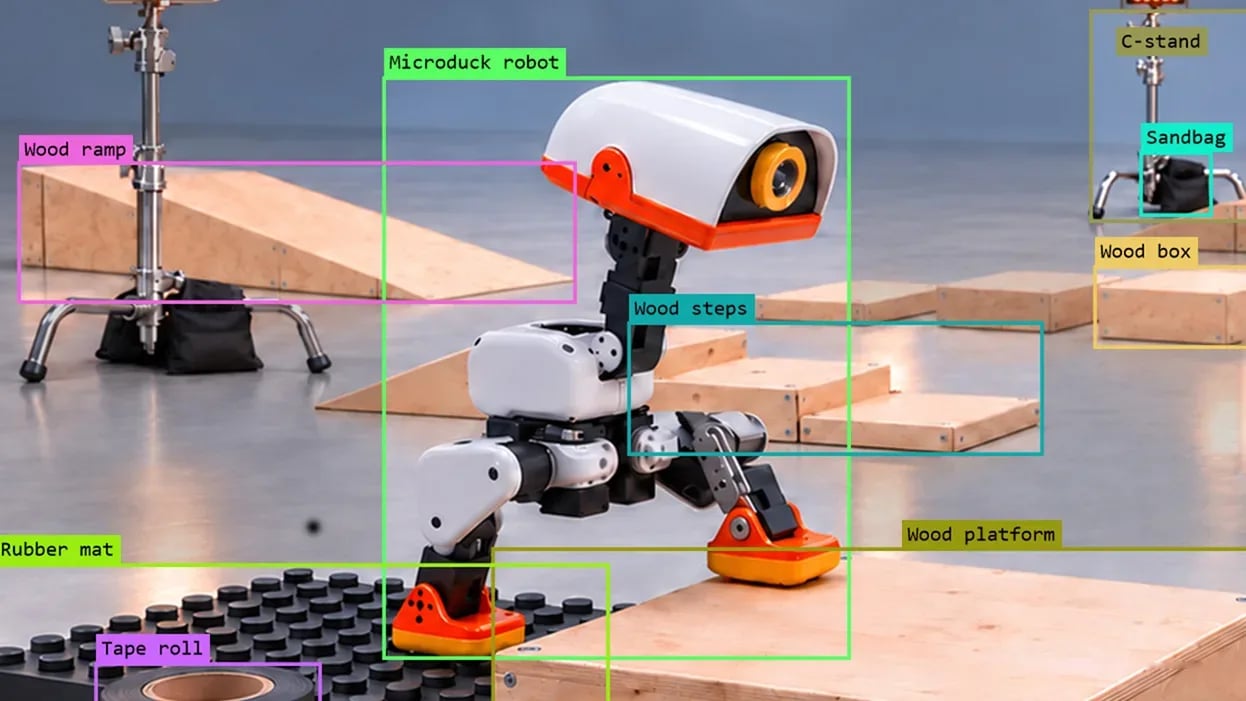
Teaching a robot to navigate an obstacle course requires more than a walking policy. It must perceive its surroundings, maintain balance, and adjust its actions when obstacles block the path ahead. Developing these capabilities connects several stages: creating assets and an environment, using physics simulation to model how the robot interacts with its environment, and training and evaluating policies in simulation.
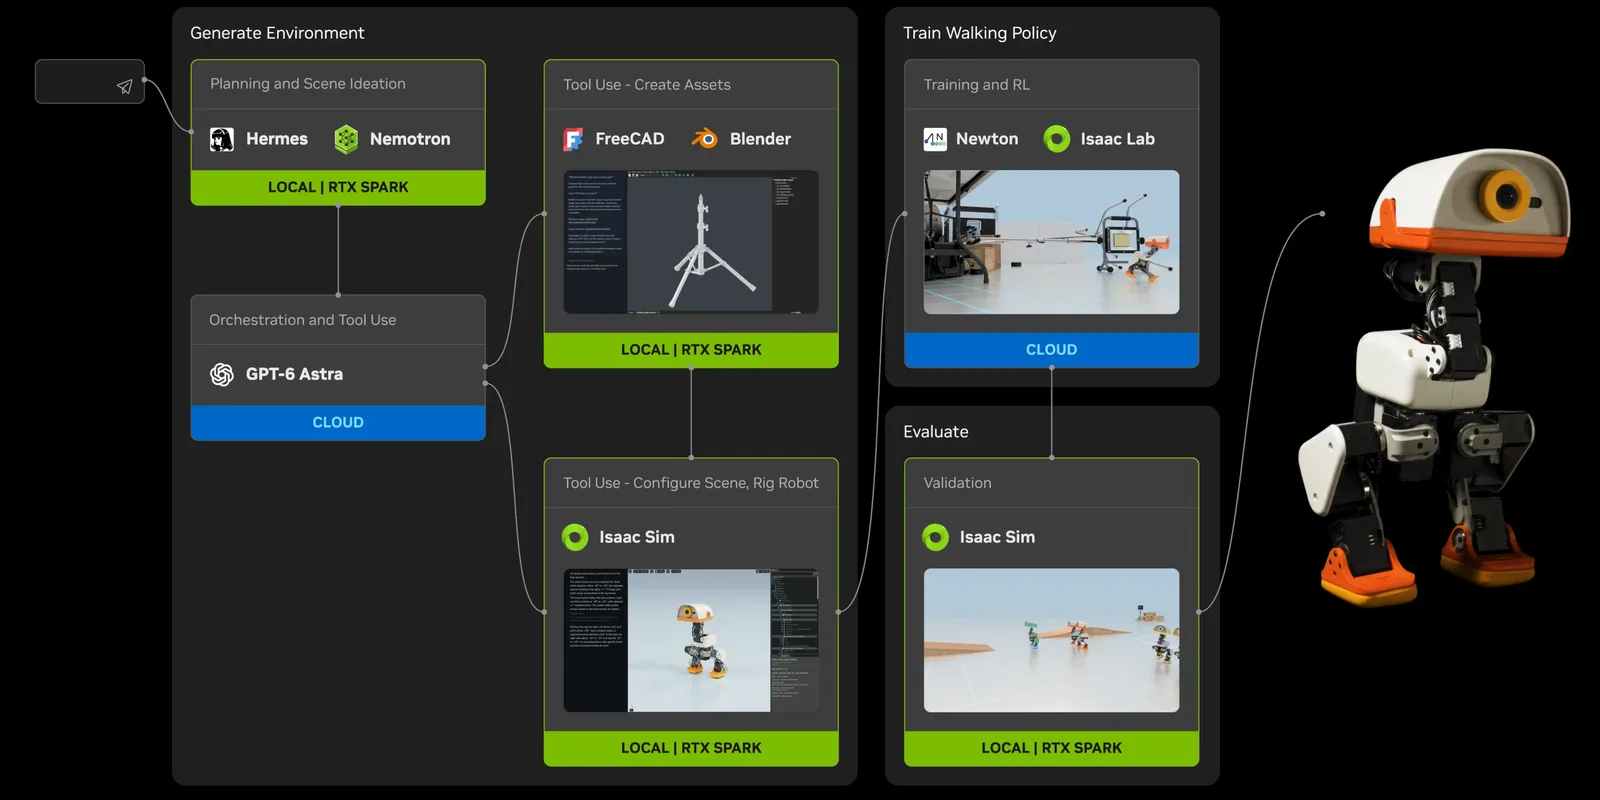
NVIDIA RTX Spark serves as a local development hub, supporting AI-assisted planning and policy validation. NVIDIA Isaac Lab provides the robot-learning framework for reinforcement learning in the cloud, while Newton models physical behavior, and NVIDIA Omniverse libraries generate simulated visual observations through RTX rendering. Trained policies return to RTX Spark for local evaluation in NVIDIA Isaac Sim.
This post walks through the workflow using Microduck as a reference robot, with Hermes, NVIDIA Nemotron, and Astra assisting with planning and preparation. You’ll learn how to create a simulated obstacle course, train a navigation policy, and evaluate its behavior in simulation—a process you can adapt to your own robots and tasks. This establishes a foundation for physical deployment, where differences between simulation and real-world behavior require further refinement.
Keep reading NVIDIA Technical Blog with Pro
This source is part of the Pro library. Unlock every premium source, AI translation and custom feeds.
Originally published on
NVIDIA Technical Blog
Keep reading
 Fly.io Blog